Next: Rectification
Up: Stereo Geometry
Previous: Epipolar Geometry
Fundamental Matrix
The fundamental matrix encodes all given geometrical constraints between a set of two stereo-images. Given a point  in the first view and its corresponding point
 in the second view in homogenous coordinates,
 fulfills the following equation

is a 3×3 matrix with rank 2. Details about the derivation can be found in [HZ00]. Some of the most important properties of are:
- Transpose
- If
 is the fundamental matrix of a pair of cameras (C,C‘), then
 is the fundamental matrix of the pair in the opposite order (C‘,C).
- Epipolar lines
- For any point x in the first image, we can find the corresponding epipolar line

 with
 and also

 .
- Epipole
- for any point

 other than the epipole
 , contains the epipole
 . Thus satisfies
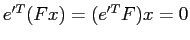
 for all . It follows that
 , i.e. is the left null-space of F. Similarly
 , i.e. is the right null-space of F.
 is the fundamental matrix of the pair in the opposite order (C‘,C).
 and also
 ,
 . Thus
 , i.e.
 , i.e. is the right null-space of F.
To compute you can use corresponding points to solve the homogeneous linear Equation 2.15. The standard technique is to use pre-conditioning followed by symmetric matrix eigendecomposition to solve for the nine elements of up to an undetermined scale factor.
In case of known camera calibration parameters the essential matrix  is the equivalent to the fundamental matrix . In this case the rotation and translation between the cameras can be computed, up to an unknown scale factor. The images are now related by the following equation
 is the essential matrix,
 and
 are ideal image coordinates. The ideal image coordinates
 have to be calculated from the original image coordinates
 , so that and are the projected coordinates for an ideal camera. An ideal camera has focal distances
 , image center
 and homogenous z-coordinate = 1. Thus the camera calibration matrix is the identical matrix
 . The essential matrix can be written as

 is the rotation matrix,
 is the translation vector between the two cameras and
 is defined as
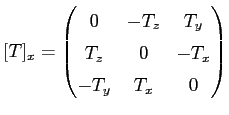
For more information about the essential matrix have a look at [Fau93,HZ00].
Next: Rectification
Up: Stereo Geometry